Autonomy and navigation for small drones and robots.
Logistics and medical evacuation, offline.
Two verticals, three solutions
Reconnaissance: the Lodestone navigation and autonomy brick, delivered to platform makers. Logistics: the Knarr copilot for logistics cells, and its Eira variant for the medical cell.
One software stack, developed in Python and ported where performance requires it.
Where we stand
Phase 0, Foundation, from October 2026 to March 2027. GNSS-free navigation, spoofing detection, the automatic logistic picture and evacuation decision support exist in simulation on open or synthetic data. Next come the first flights on a partner platform, an evaluation of Knarr and Eira, and the first letters of intent.
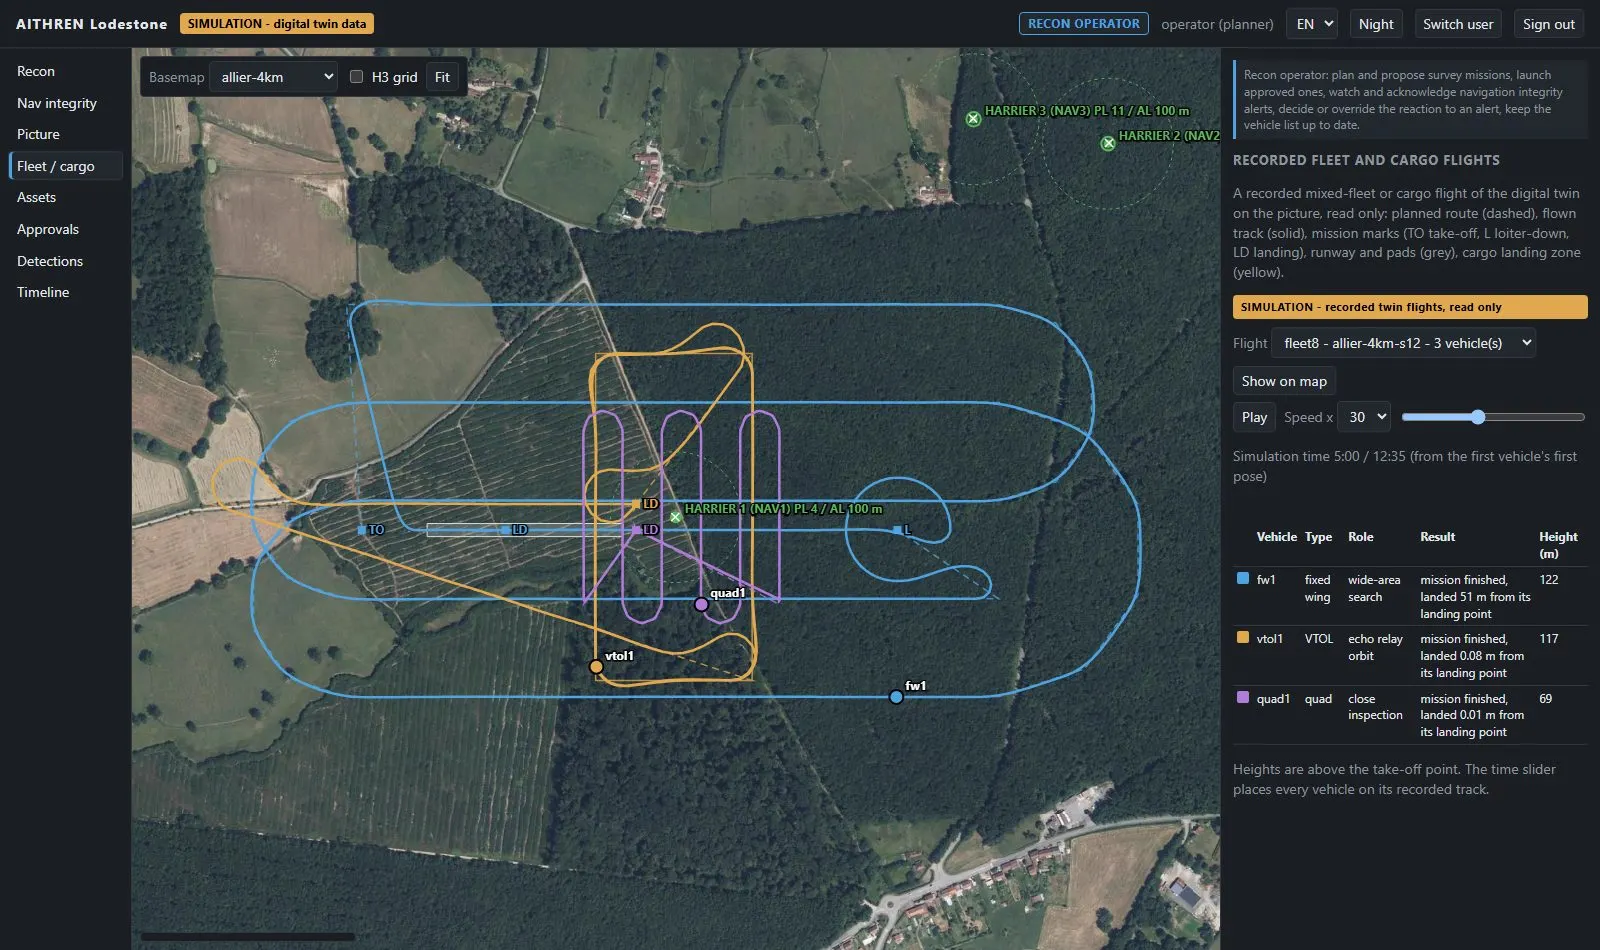
- Oct 2026 → Mar 2027 Phase 0, Foundation
- 2027 → 2028 Phase 1, Prove
- 2028 → 2030 Phases 2 and 3, Qualify
The founder
[To be completed by the founder: name, background, licensed drone pilot, security clearance. Photo or not.]
Defence and dual uses
Our solutions are designed for defence. The same bricks serve civil protection and rescue: drone navigation where GNSS is gone, night search for people, crisis logistics to isolated areas, coordination of medical evacuations in a mass-casualty event. No lethal function, in any use.
Partners wanted
Platform makers and integrators for flight trials; units and schools for an evaluation of Knarr or Eira on a training scenario; funders of the foundation phase.